

Computer vision QC across 3 factory lines
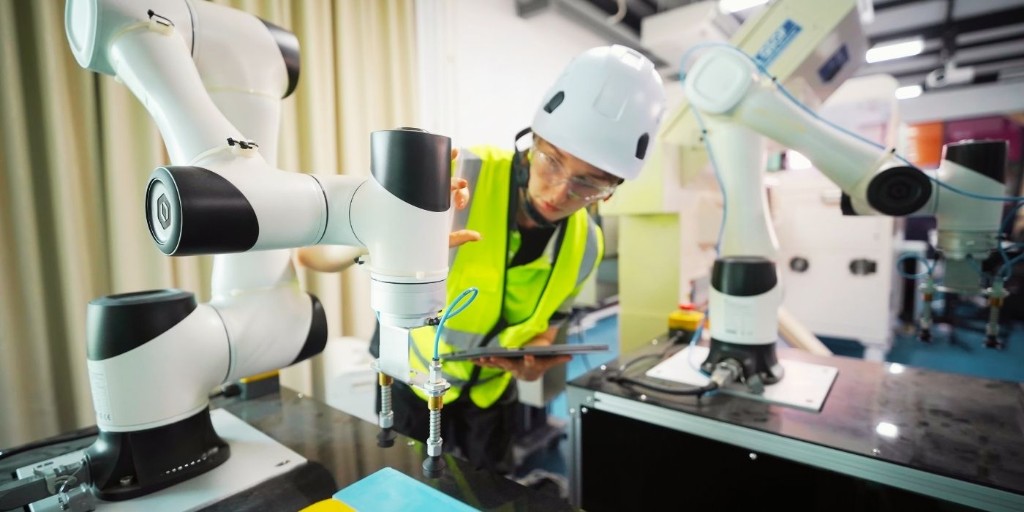
Real-time defect detection deployed on production lines.
Key Details
| Challenge | Manual QC missed defects at line speed and tired operators. |
|---|---|
| Solution | A vision station per line with operator UX and reject signals to PLC. |
| Technologies | OpenCV, PyTorch, NVIDIA Jetson, OPC-UA |
Technologies used
 OpenCV
 PyTorch
 NVIDIA
 Python
 Docker
 MQTT
Client background
A manufacturer running three similar lines relied on manual QC at line speed. Escape rates rose on later shifts, and false rejects from earlier automation attempts had eroded operator trust.
Key challenges
- Lighting drift and vibration made naive models unstable between shifts.
- Latency budgets left little room for cloud round-trips.
- False rejects vs. misses required careful threshold and UX design.
- Reject signals had to integrate cleanly with existing PLC logic.

What we built
- Edge inference on Jetson per line with OpenCV/PyTorch defect models.
- Operator review UI for ambiguous cases without stopping the line.
- OPC-UA / PLC reject pulse with safe defaults on model uncertainty.
- Monitoring for lighting drift, latency and false-reject rates.
Project team: 8 engineers across AI/ML, backend and domain specialists — delivery over 24 weeks.
How we delivered
01
Floor
Assessed lighting, camera mounts and PLC interfaces on each line.
02
Pilot
Validated on one line before touching the other two.
03
Integrate
Wired reject signals and trained operators on the review UX.
04
Scale
Cloned the station design across three lines with shared model ops.
Business impact
3 linesIn production
LowerEscape rate
StableFalse rejects